Autonomous Mobile Robots for Smart Warehouse Logistics Optimization
DOI:
https://doi.org/10.46604/peti.2026.16691Keywords:
Autonomous mobile robots, smart warehouse, logistics optimization, path planning, fleet managementAbstract
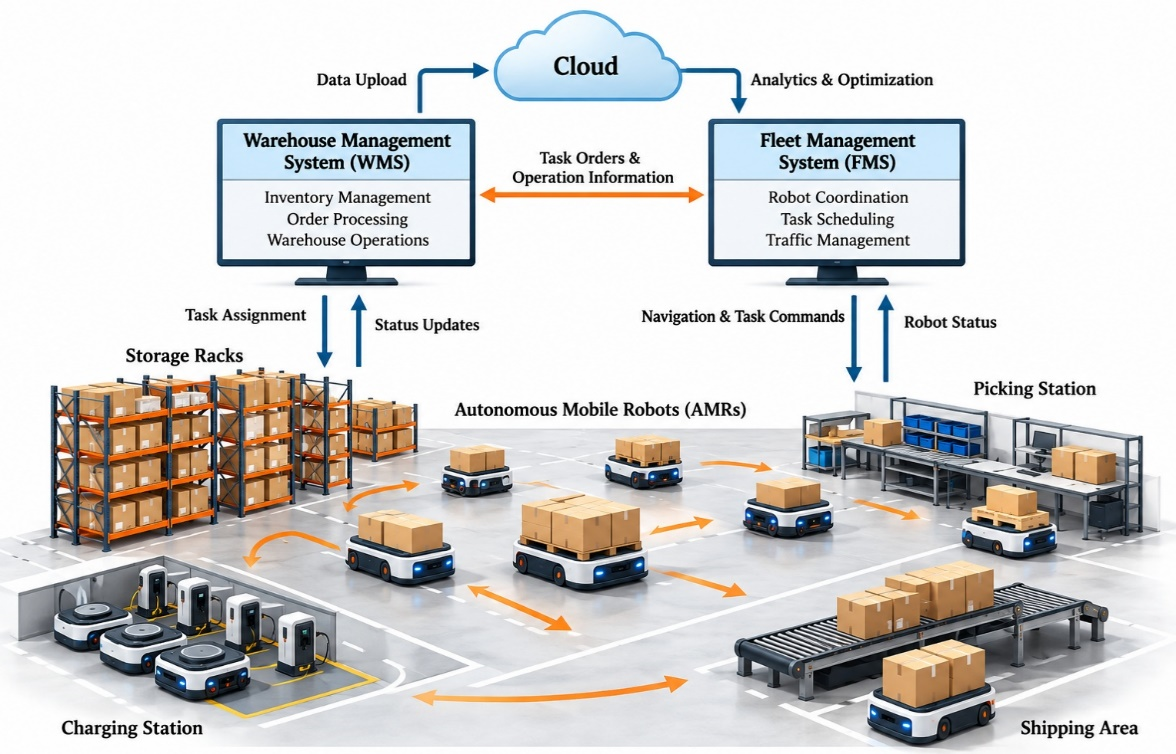
This study investigates the optimization of smart warehouse logistics using autonomous mobile robots (AMRs) and proposes an integrated framework for improving order fulfillment, routing efficiency, and warehouse throughput. The proposed framework combines sensor-based autonomous navigation, a warehouse management system, fleet coordination, reinforcement-learning-based task allocation, dynamic path planning, and energy-aware scheduling. A simulated warehouse comprising 1,000 storage locations and 50 AMRs is used for performance evaluation. Compared with manual warehouse operations, the proposed AMR system reduces average order fulfillment time from 18.4 to 11.2 min (39.1% reduction) and increases throughput from 320 to 470 orders/hour (a 46.9% increase). Furthermore, worker travel distance decreases by 67.3%, while operational cost decreases by 34.4%. The results demonstrate that coordinated AMR deployment can significantly improve warehouse productivity, operational flexibility, and resource utilization, supporting the development of intelligent Industry 4.0 logistics systems.
References
G. Fragapane, R. de Koster, F. Sgarbossa, and J. O. Strandhagen, “Planning and Control of Autonomous Mobile Robots for Intralogistics: Literature Review and Research Agenda,” European Journal of Operational Research, vol. 294, no. 2, pp. 405-426, 2021.
S. Franke, R. de Koster, C. Reining, and H. Celik, “Automated and Autonomous Mobile Robots in Warehousing: Definitions, Autonomy Levels, and Research Directions,” Journal of Intelligent & Robotic Systems, vol. 112, article no. 74, 2026.
M. Wesselhöft, J. Hinckeldeyn, and J. Kreutzfeldt, “Controlling Fleets of Autonomous Mobile Robots with Reinforcement Learning: A Brief Survey,” Robotics, vol. 11, no. 5, article no. 85, 2022.
T. Lackner, J. Hermann, C. Kuhn, and D. Palm, “Review of Autonomous Mobile Robots in Intralogistics: State-of-the-Art, Limitations and Research Gaps,” Procedia CIRP, vol. 130, pp. 930-935, 2024.
E. E. Turhanlar, B. Y. Ekren, and T. Lerher, “Autonomous Mobile Robot Travel under Deadlock and Collision Prevention Algorithms by Agent-Based Modelling in Warehouses,” International Journal of Logistics Research and Applications, vol. 27, no. 8, pp. 1322-1341, 2024.
Y. Zhang and J. U. Abellera, “Autonomous Mobile Robotics in Smart Warehousing: A Cyber-Physical Systems Approach to Inventory Management,” Future Technology, vol. 4, no. 4, pp. 59-71, 2025.
M. T. Benavides-Robles, G. H. Valencia-Rivera, J. M. Cruz-Duarte, I. Amaya, and J. C. Ortiz-Bayliss, “Robotic Mobile Fulfillment System: A Systematic Review,” IEEE Access, vol. 12, pp. 16767-16782, 2024.
Í. R. da C. Barros and T. P. Nascimento, “Robotic Mobile Fulfillment Systems: A Survey on Recent Developments and Research Opportunities,” Robotics and Autonomous Systems, vol. 137, article no. 103729, 2021.
L. Xie, N. Thieme, and H. Li, “From Simulation to Real-World Robotic Mobile Fulfillment Systems,” Logistics Research, vol. 12, no. 1, pp. 1-13, 2019.
L. Zhen, Z. Tan, R. de Koster, and S. Wang, “How to Deploy Robotic Mobile Fulfillment Systems,” Transportation Science, vol. 57, no. 6, pp. 1671-1695, 2023.
J. Wang and S. Zheng, “Research on Path Planning Algorithms of Multiple Mobile Robots in Intelligent Warehousing,” Proceedings of the 2022 International Conference on Artificial Life and Robotics (ICAROB 2022), vol. 27, pp. 313-317, 2022.
J. Chu, Y. Tian, Q. Yue, and Y. Huang, “Task Allocation and Path Planning for Multi-Robot Systems in Intelligent Warehousing,” Journal of Northwestern Polytechnical University, vol. 42, no. 5, pp. 929-938, 2024.
X. Li, X. Yang, C. Zhang, and M. Qi, “A Simulation Study on the Robotic Mobile Fulfillment System in High-Density Storage Warehouses,” Simulation Modelling Practice and Theory, vol. 112, article no. 102366, 2021.
S. Wu, C. Chi, W. Wang, and Y. Wu, “Research of the Layout Optimization in Robotic Mobile Fulfillment Systems,” International Journal of Advanced Robotic Systems, vol. 17, no. 6, 2020.
R. Yuan, J. Li, W. Wang, J. Dou, and L. Pan, “Storage Assignment Optimization in Robotic Mobile Fulfillment Systems,” Complexity, vol. 2021, no. 1, article no. 4679739, 2021.
Downloads
Published
Issue
Section
License
Copyright (c) 2026 Wai Yie Leong

This work is licensed under a Creative Commons Attribution-NonCommercial 4.0 International License.
Submission of a manuscript implies: that the work described has not been published before that it is not under consideration for publication elsewhere; that if and when the manuscript is accepted for publication. Authors can retain copyright of their article with no restrictions. Also, author can post the final, peer-reviewed manuscript version (postprint) to any repository or website.

Since Oct. 01, 2015, PETI will publish new articles with Creative Commons Attribution Non-Commercial License, under The Creative Commons Attribution Non-Commercial 4.0 International (CC BY-NC 4.0) License.
The Creative Commons Attribution Non-Commercial (CC-BY-NC) License permits use, distribution and reproduction in any medium, provided the original work is properly cited and is not used for commercial purposes
How to Cite